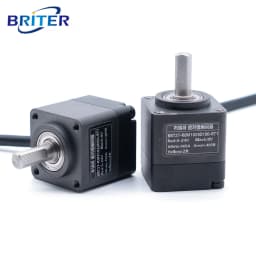
27mm Absolute Rotary Encoder RS485 RS232 CAN CANopen Modbus RTU Communication 6mm Solid Shaft IP54
80.19$
60.15$
Quantity:
1
Availability:
Color
Model Number
Ships From
Card Payments
Crypto Payments
Easy return
Reliable Shipping
Official website: www.briterencoder.com
More information (pecifications, drawings, 3D models, manuals)
please visit our our website (supports multiple languages).
Product Showcase
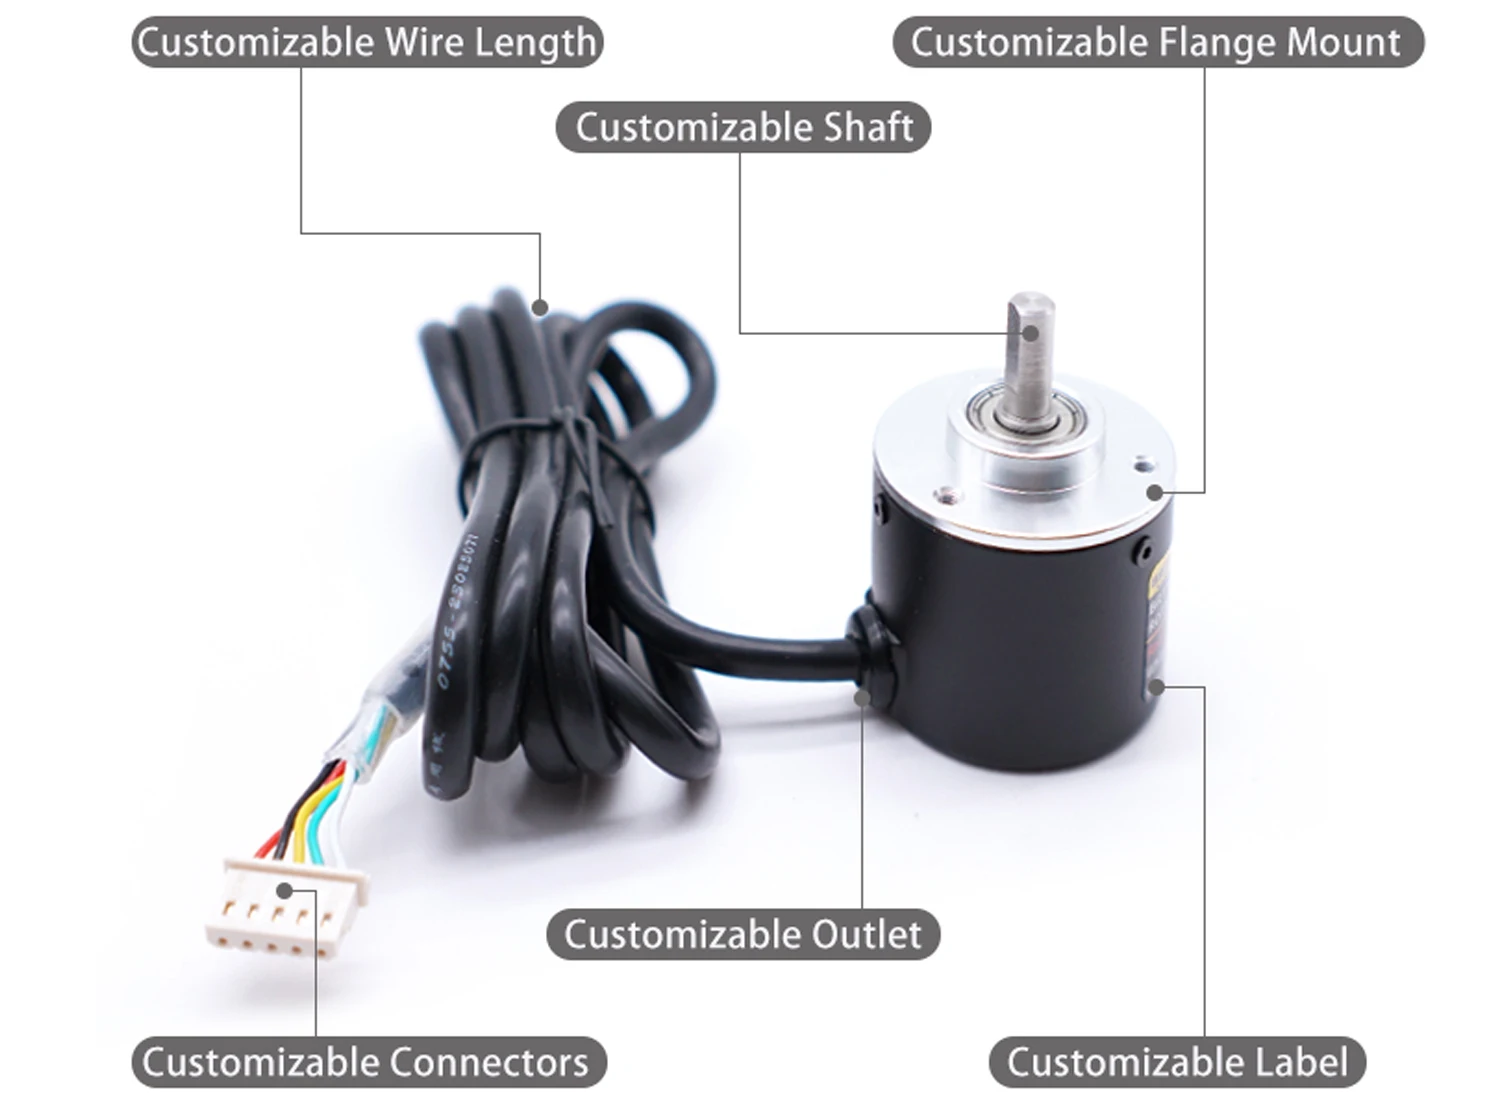
Customizable Support
For more information, please contact with us.(email:
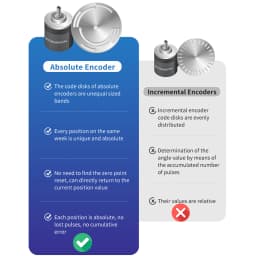
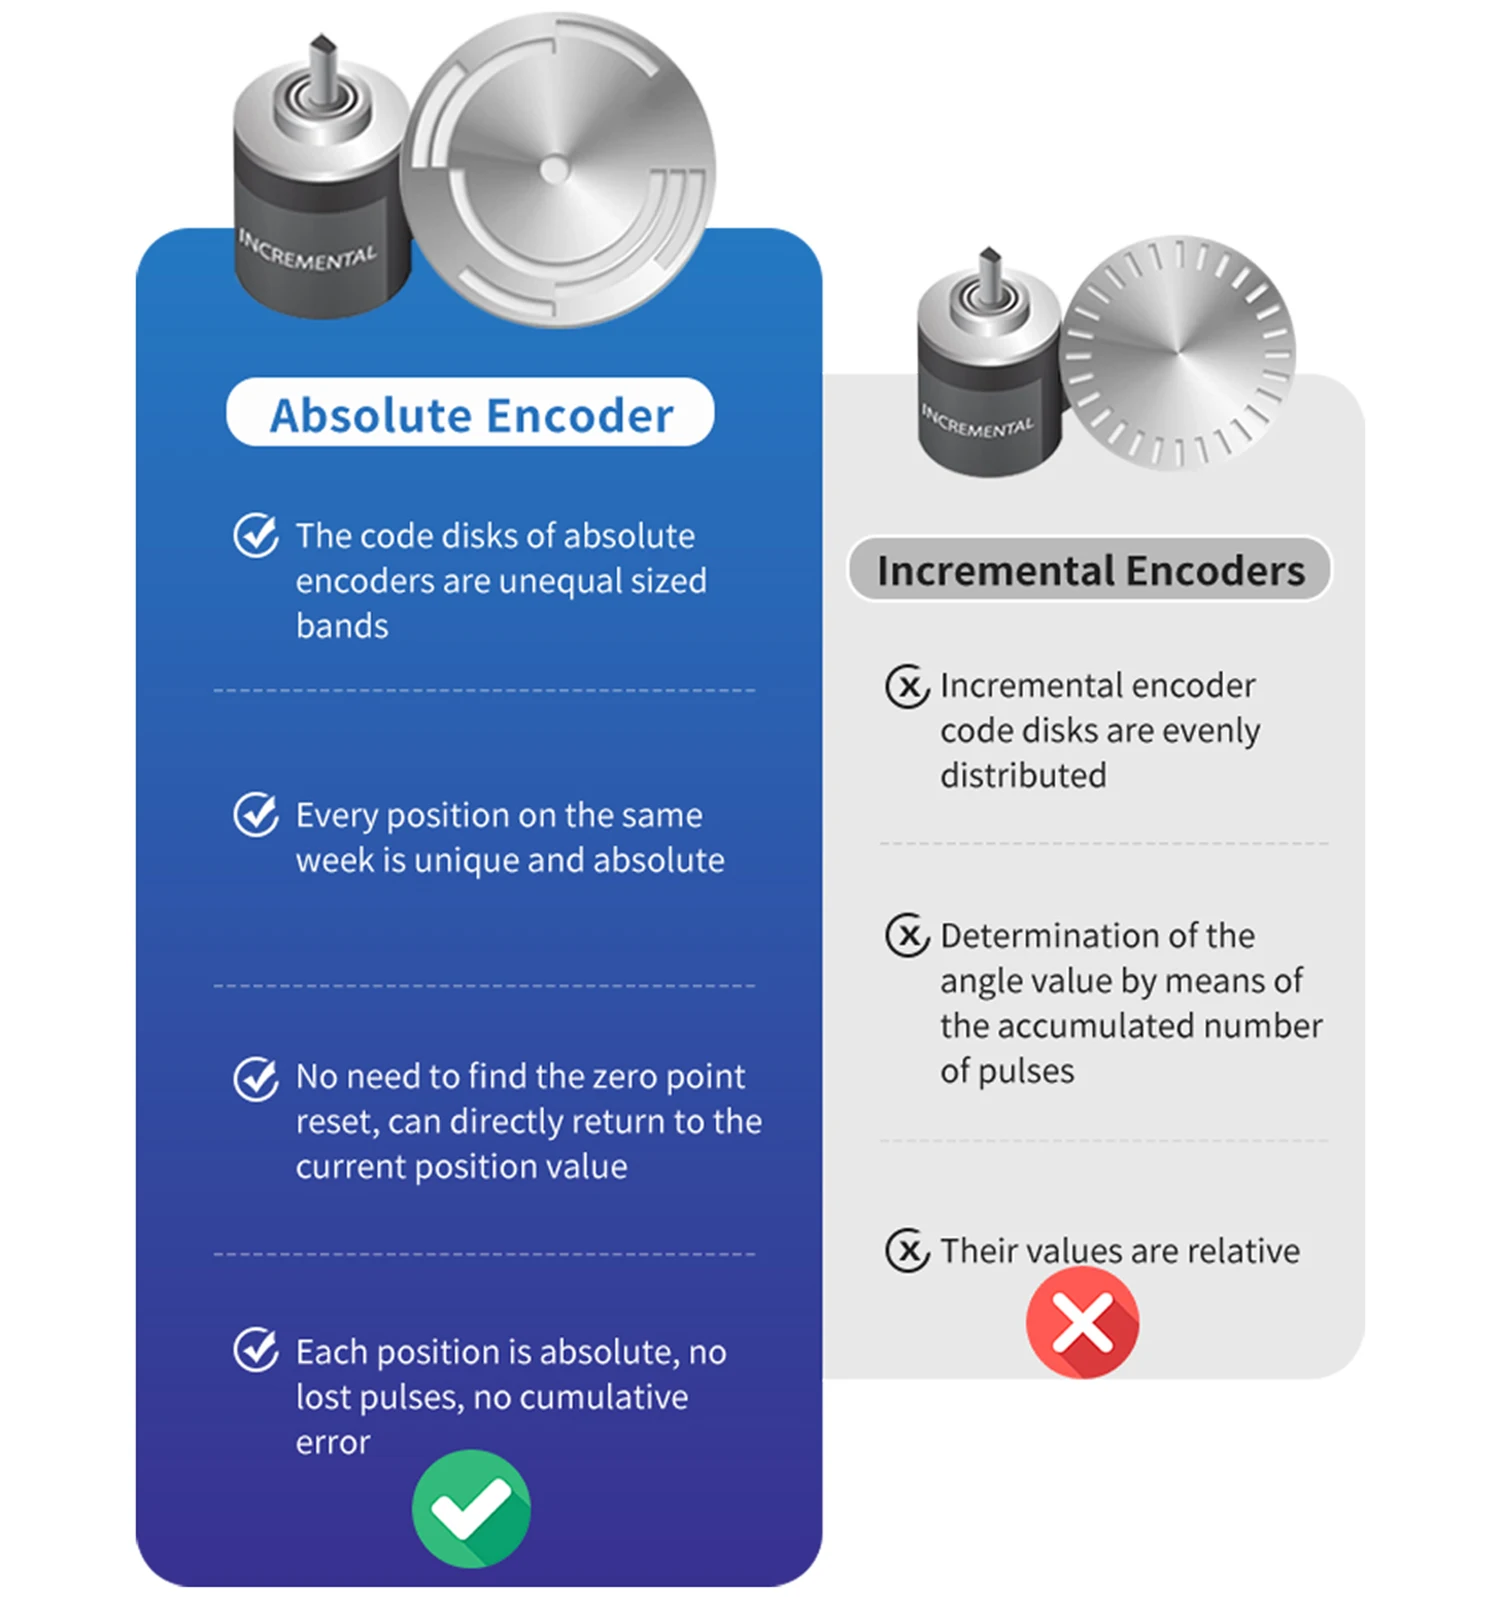
Absolute Encoder
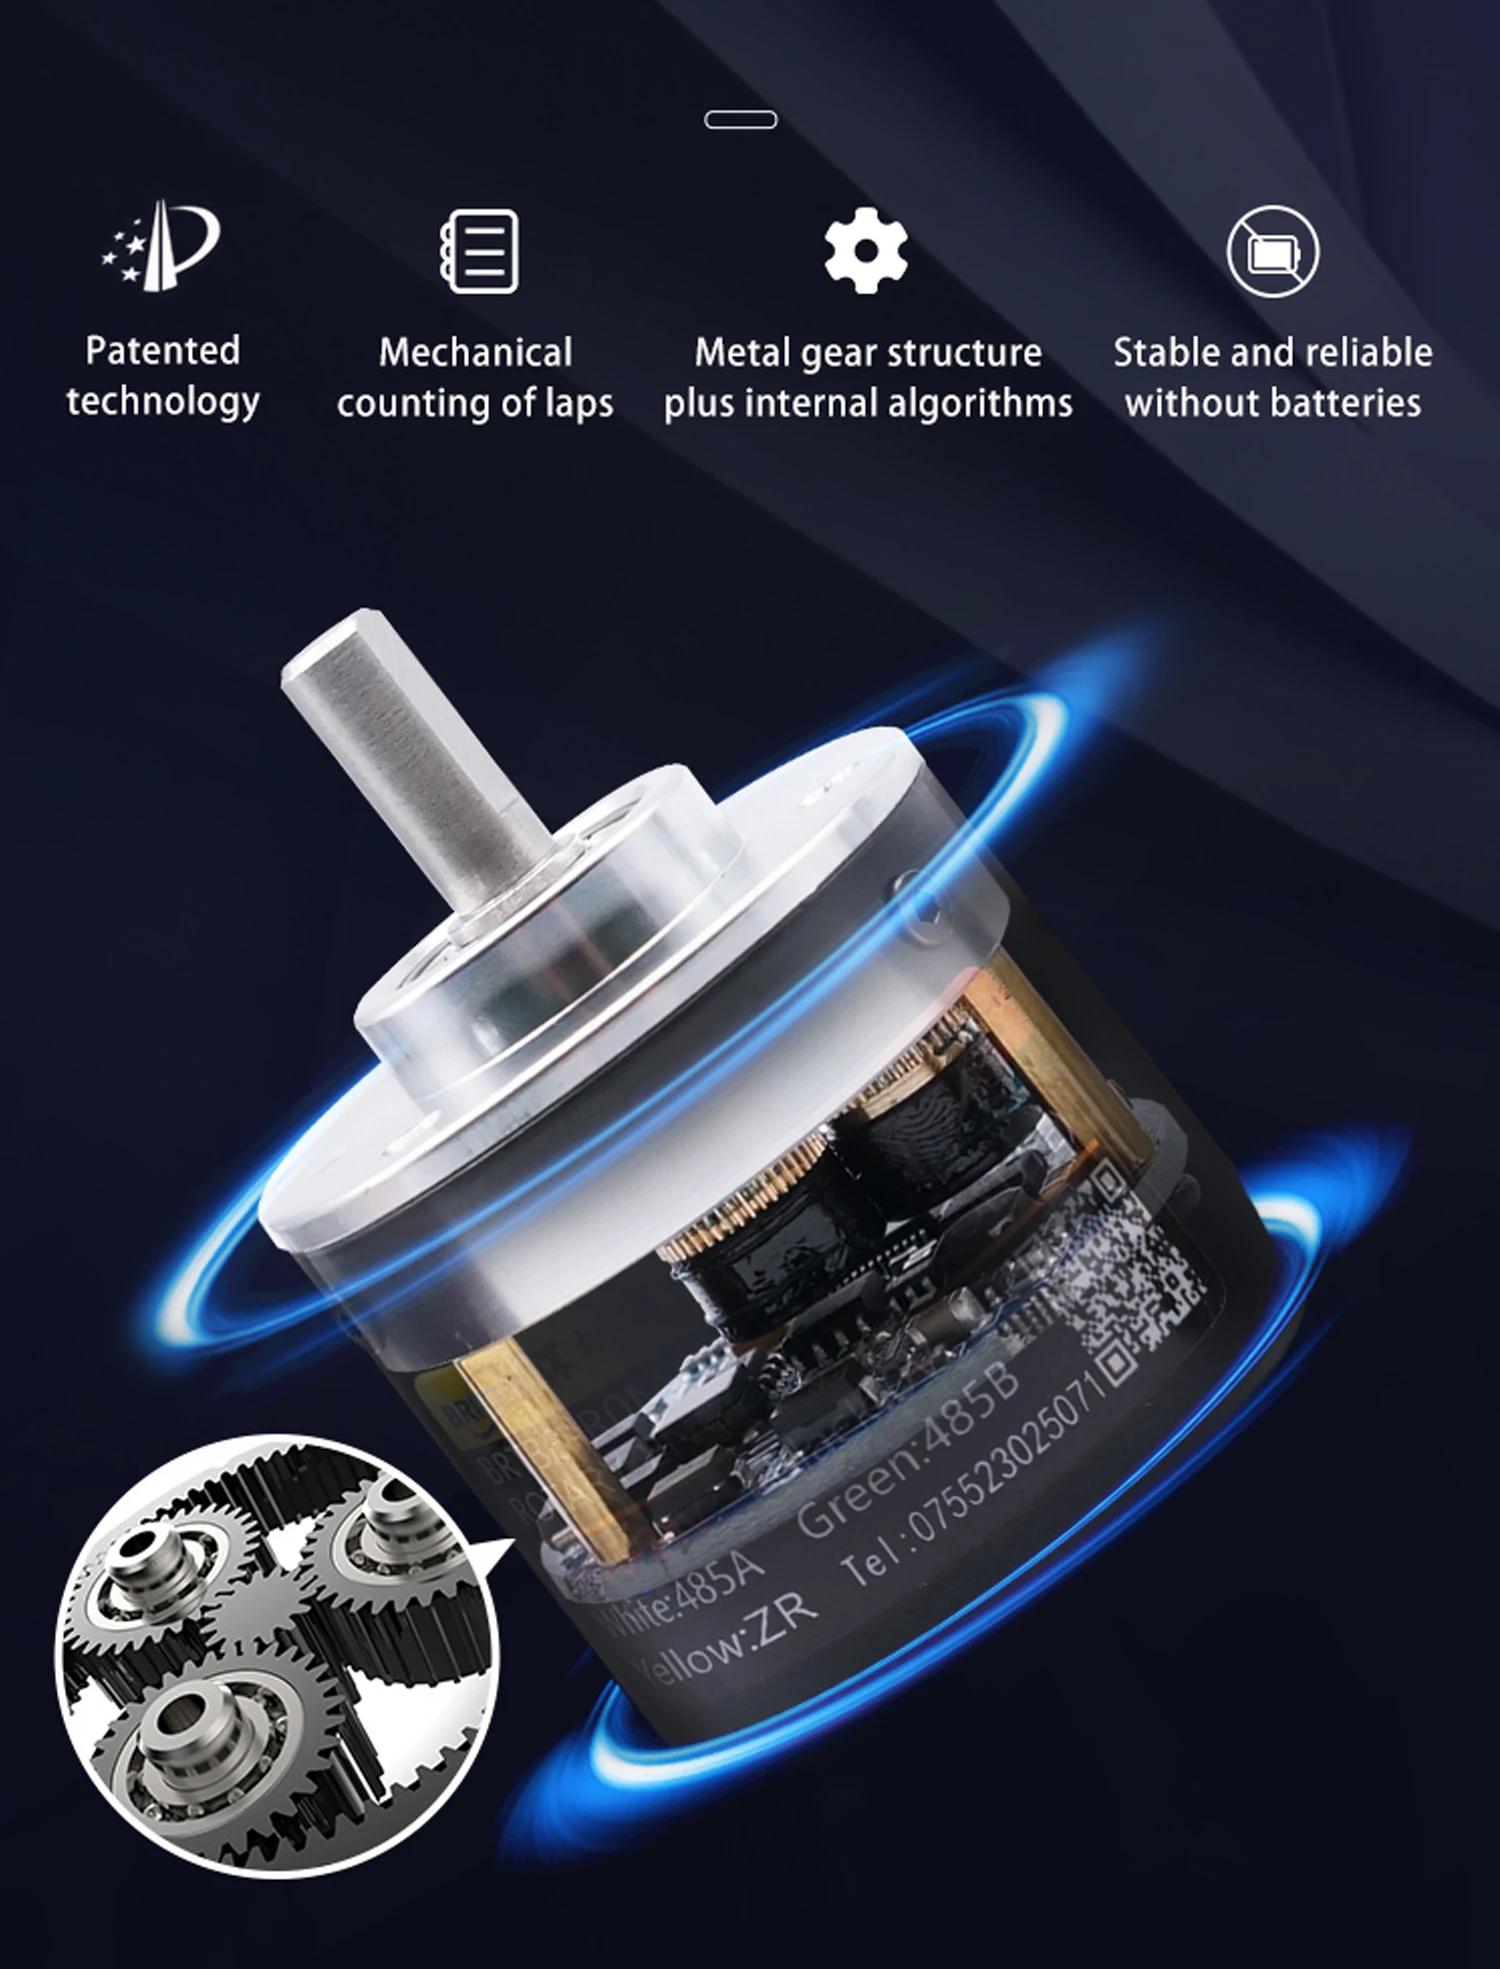
Power-off memory
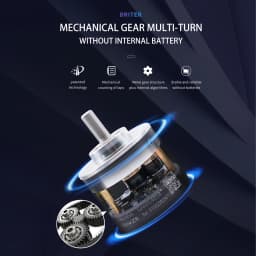
Mechanical gear multi-turn
without internal battery
Single Turn
For a clock with a “minute hand" : it can only record the position of the"minute hand" within the 0~360° rotation cycle.
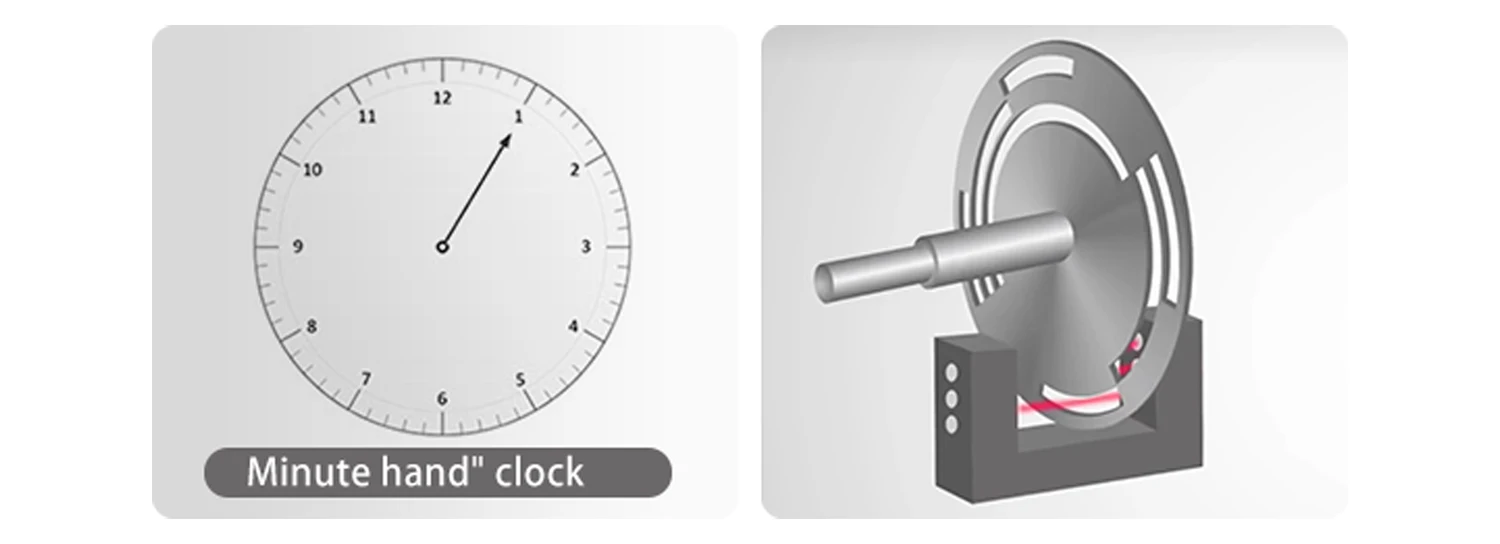
For example:
with a single-turn encoder, when it rotates to "50", after power off and then powering back on, you can directly read the angle value.
The mechanical structure of a single-turn encoder can achieve continuous rotation.
Due to being able to retain data only within a single revolution after a power outage, it is defined as a single-turn encoder.
Normal mode:
When more than one lap is completed, the value resets to 0 and starts counting again.
Multi-lap mode:
In a continuous power supply situation, it can count multiple laps.
Multi-Turn
A clock with"minute hand + hour hand":
It can provide feedback on the position of the"minute hand" within the 0-360°cycle. It can also provide feedback on the numberof rotations made by the "minute hand' through the "hour hand".
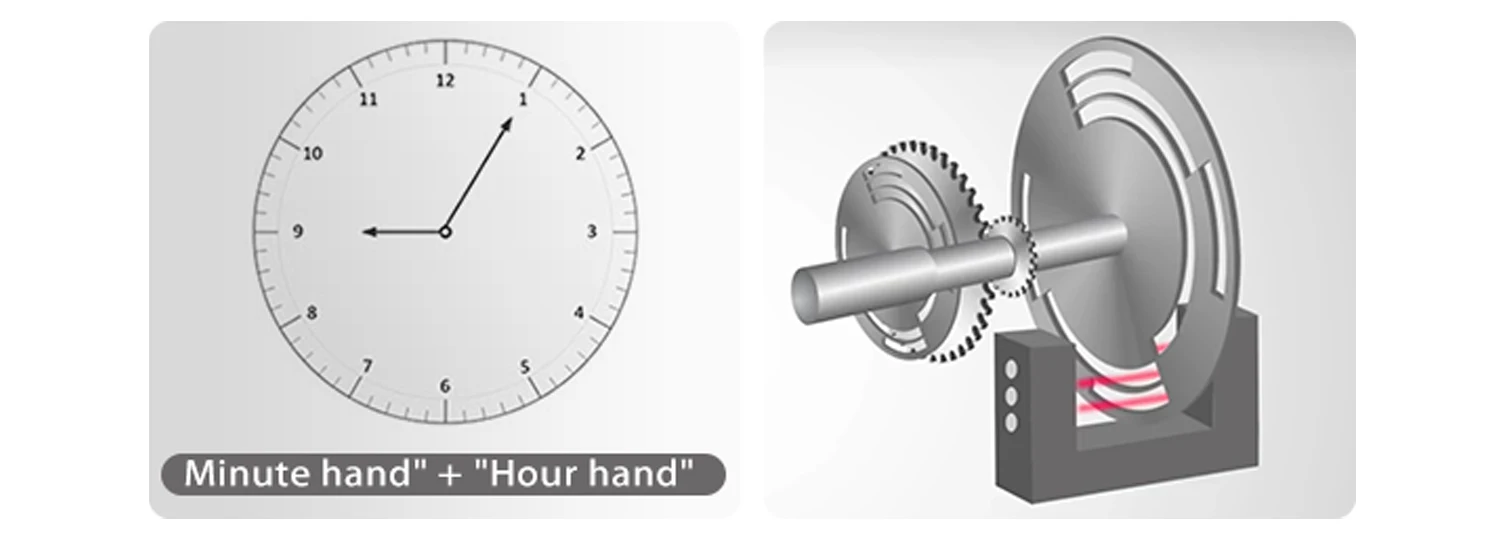
For example:
A 24-turn encoder can be turned to 2 turns and 50 degrees, and can be read directly after power-off and power-on. When it exceeds 24 turns, the value will start counting from 0 again.
The mechanical structure of a multi-turn encoder allows for continuous rotation.
It can remember the data within a single turn and the number of turns even after a power outage. So it defined as multi-turns
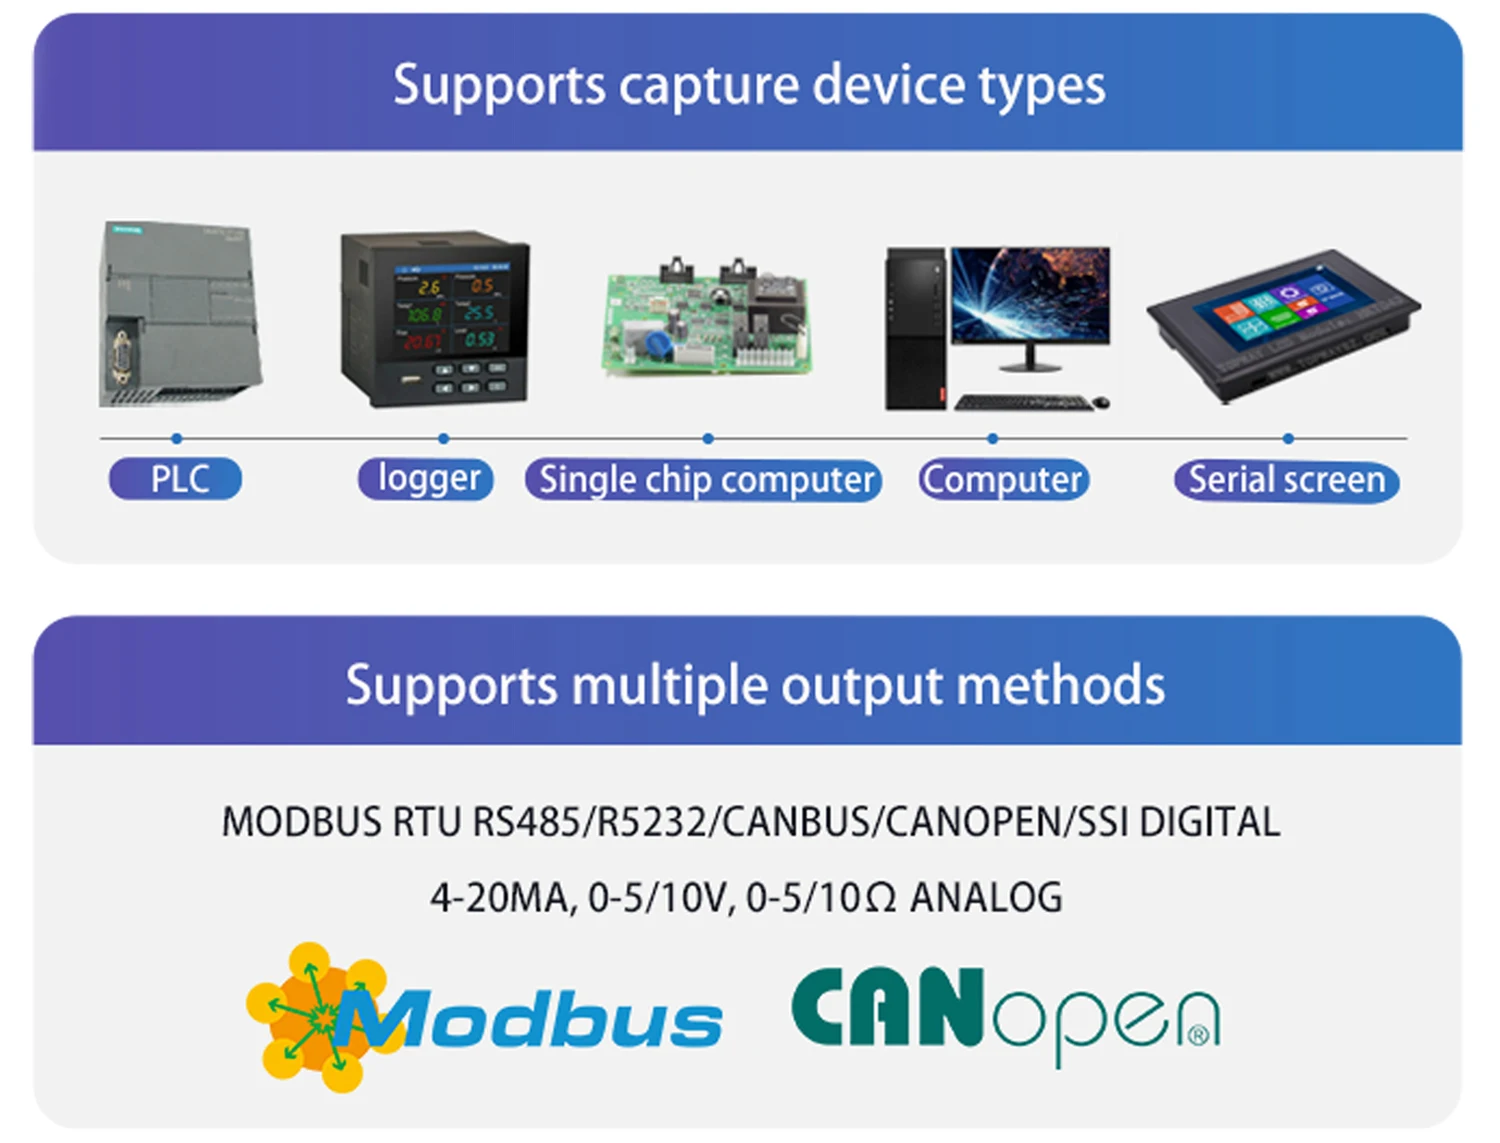
Support various PLCs
RS485 ModBbus RTU, CANopen, SSI, Analog
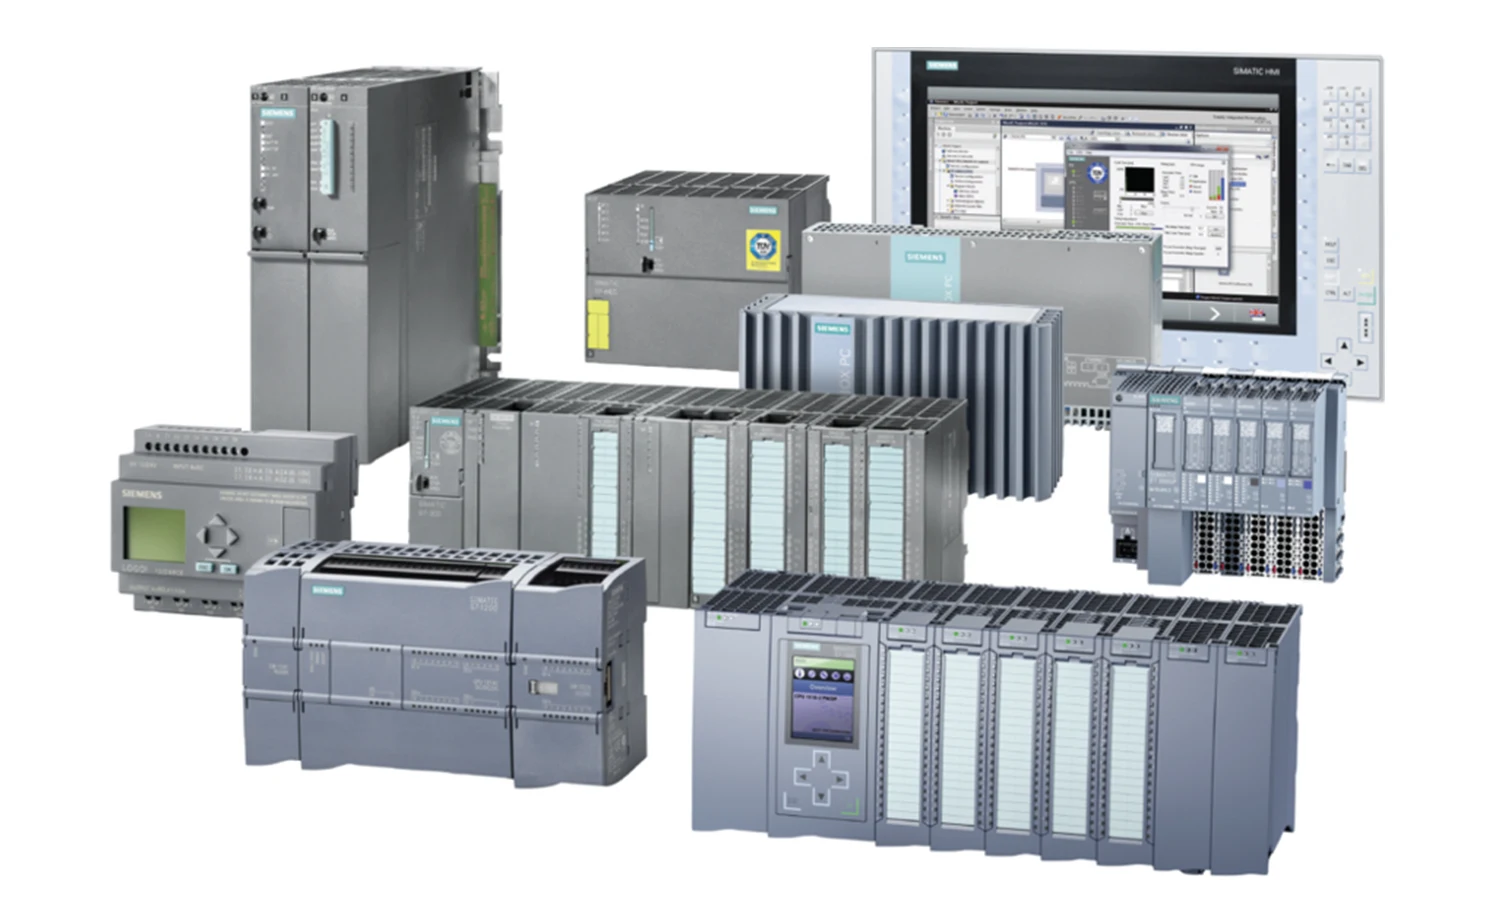
Supported PLCs of Siemens, Xinjie, Omron, Mitsubishi, Delta, etc
PLCs with RS485 or CANOPEN interfaces are supported.
Provide detailed connection example tutorial, professional PLC technical support.
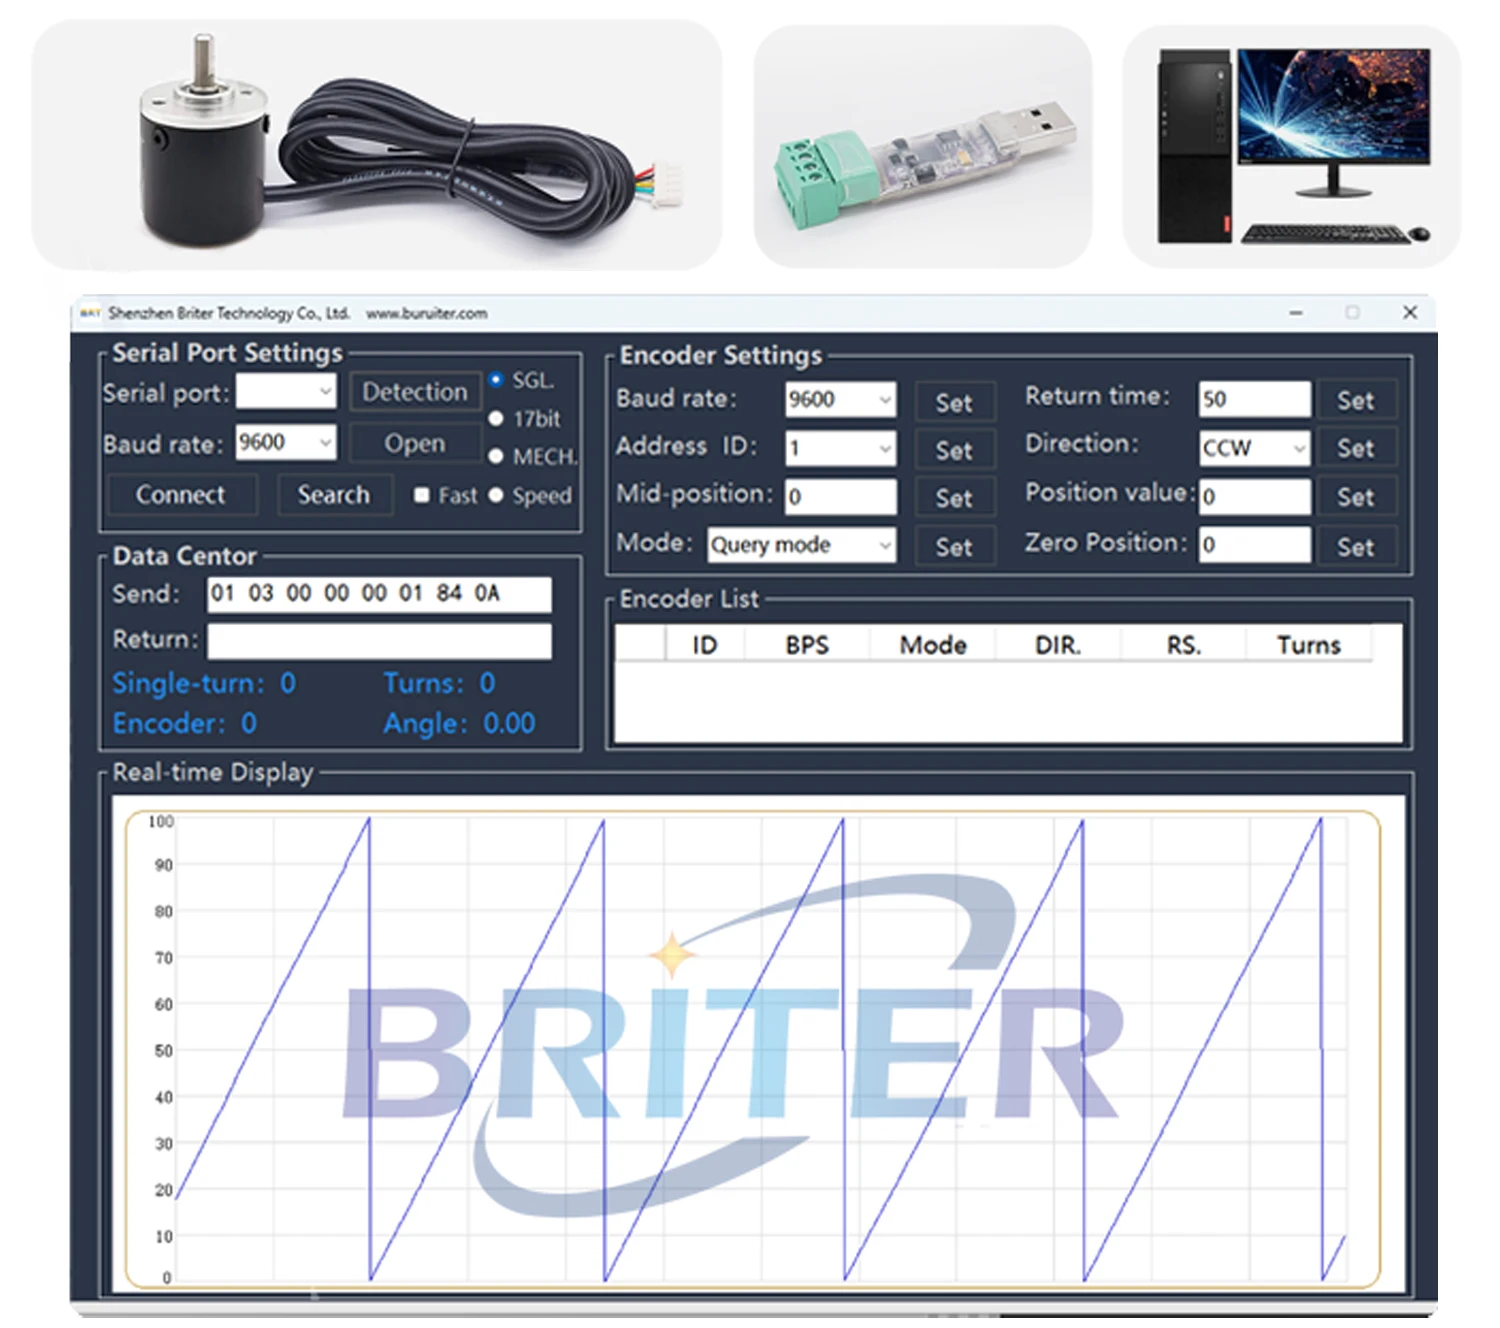
PC Software
RS485/RS232/CANbus Parameters such as baud rate, ID and return mode can be set via the software, Official website:
www.briterencoder.com
Production
Download Specification
more information, please visit:
www.briterencoder.com
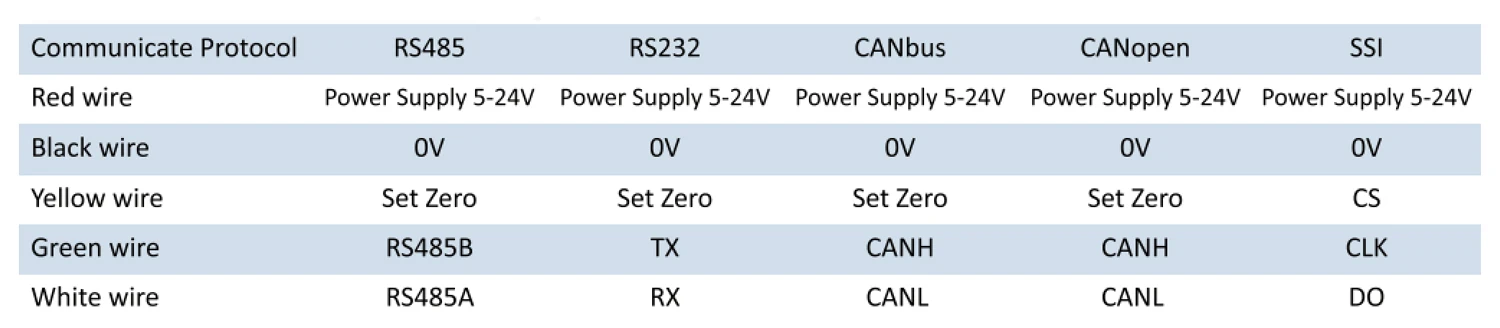
Interface(RS485/RS232/CANbus/CANopen/SSI):
Notes:
The yellow wire is a functional wire. It can be used for setting encoder zero position or restoring encoder factory settings.
When the encoder is in normal use, the yellow wire should be suspended and not be connected.
Three simple ways to set absolute encoder to zero position?
Method 1. Connect yellow wire to ground (black wire) more than 100mS. After set zero, please separate the yellow and black wire.
Method 2. After right connected the wires according to the wiring definition. send set zero position command according to the user manual.
Method 3. Use the host computer software provided by our company (BriterEncoder).
How to restore the absolute encoder to factory settings?
Step 1, After power off, connect the yellow wire to the black wire.
Step 2, power on, and hold for two minutes.
Step 3, power off, then separate the yellow wire from the black wire. now the rotary encoder ha restored to factory settings.
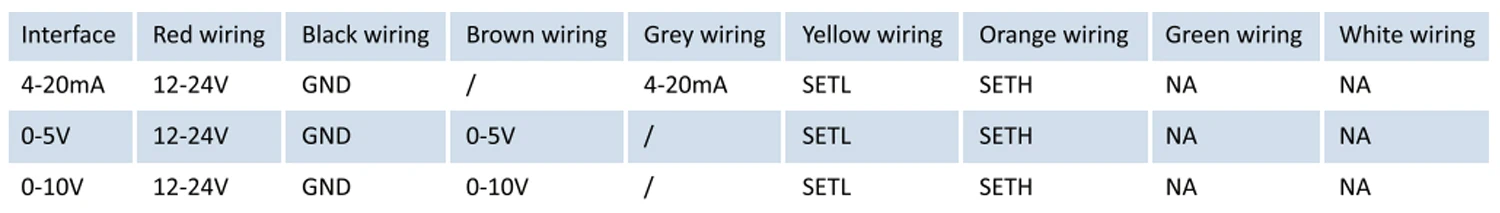
Analog(0-5V/0-10V/4-20mA)
Dimension drawings and 3D file download
more information, please visit:
www.briterencoder.com
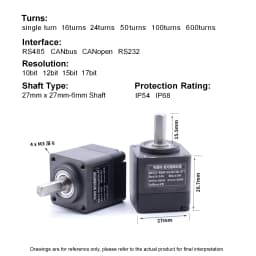
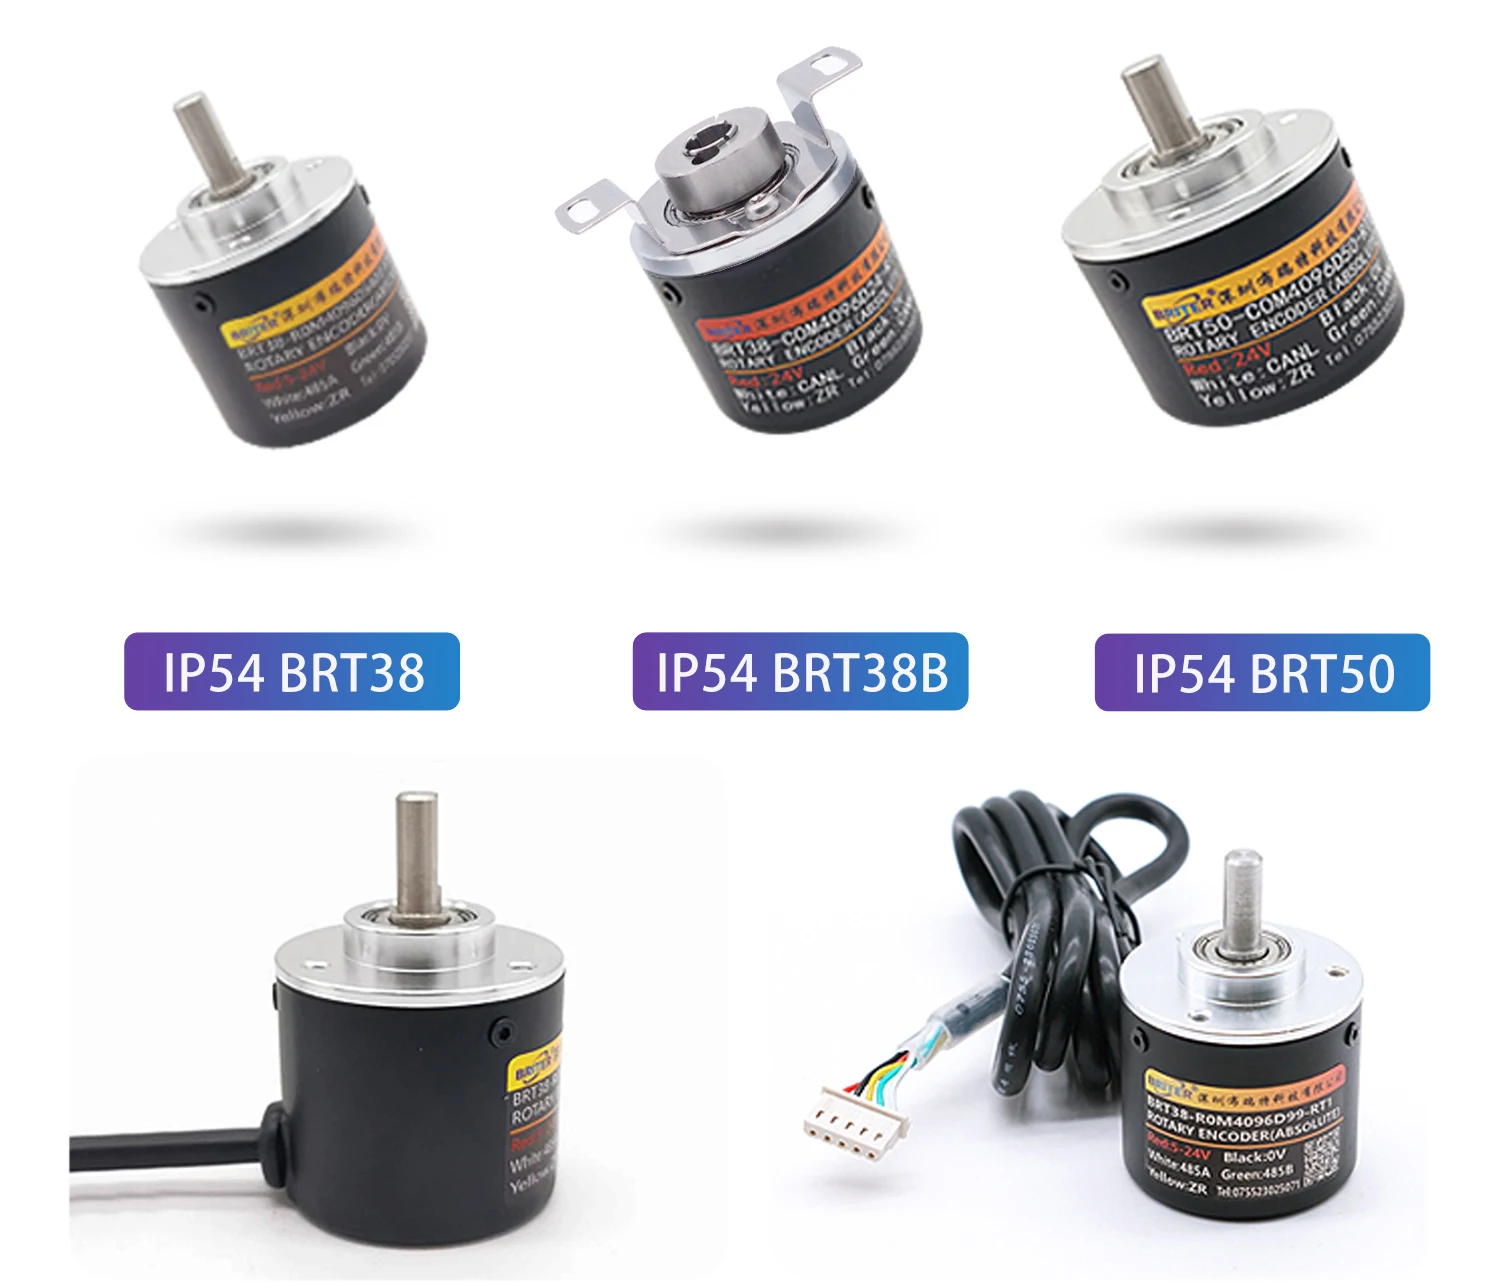
BRT38-6mm Solid Shaft IP54 (Below)
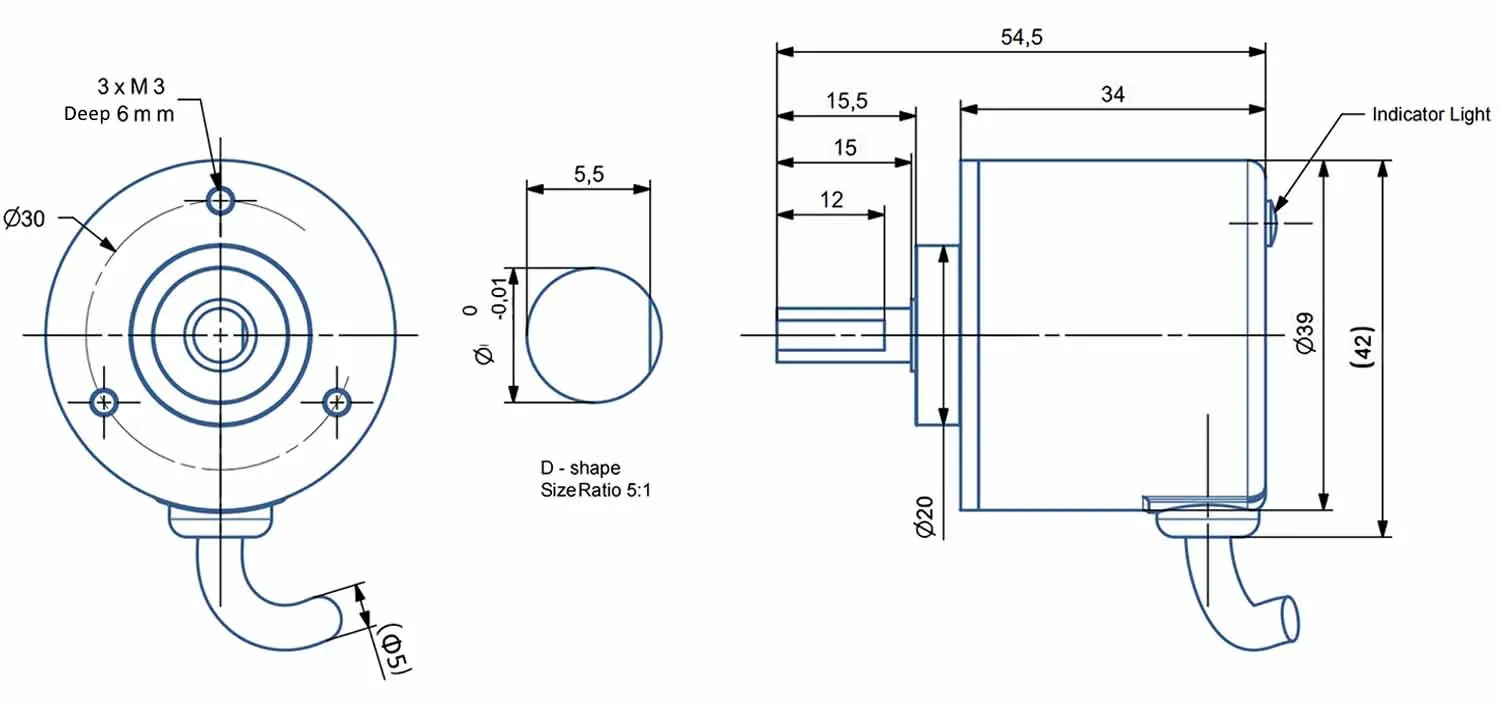
BRT38-8mm Blind Hollow Shaft IP54 (Below)
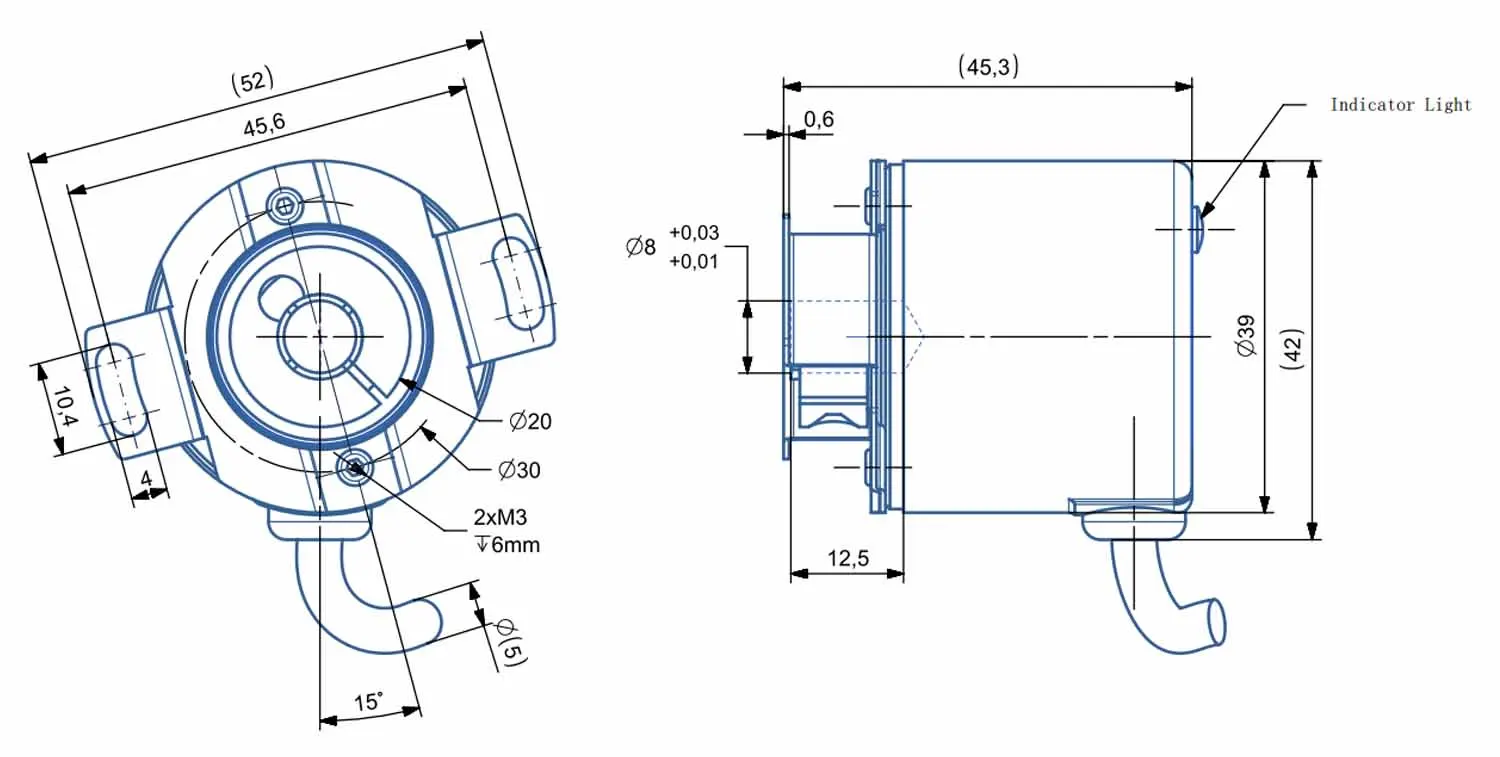
BRT50-8mm Solid Shaft IP54 (Below)
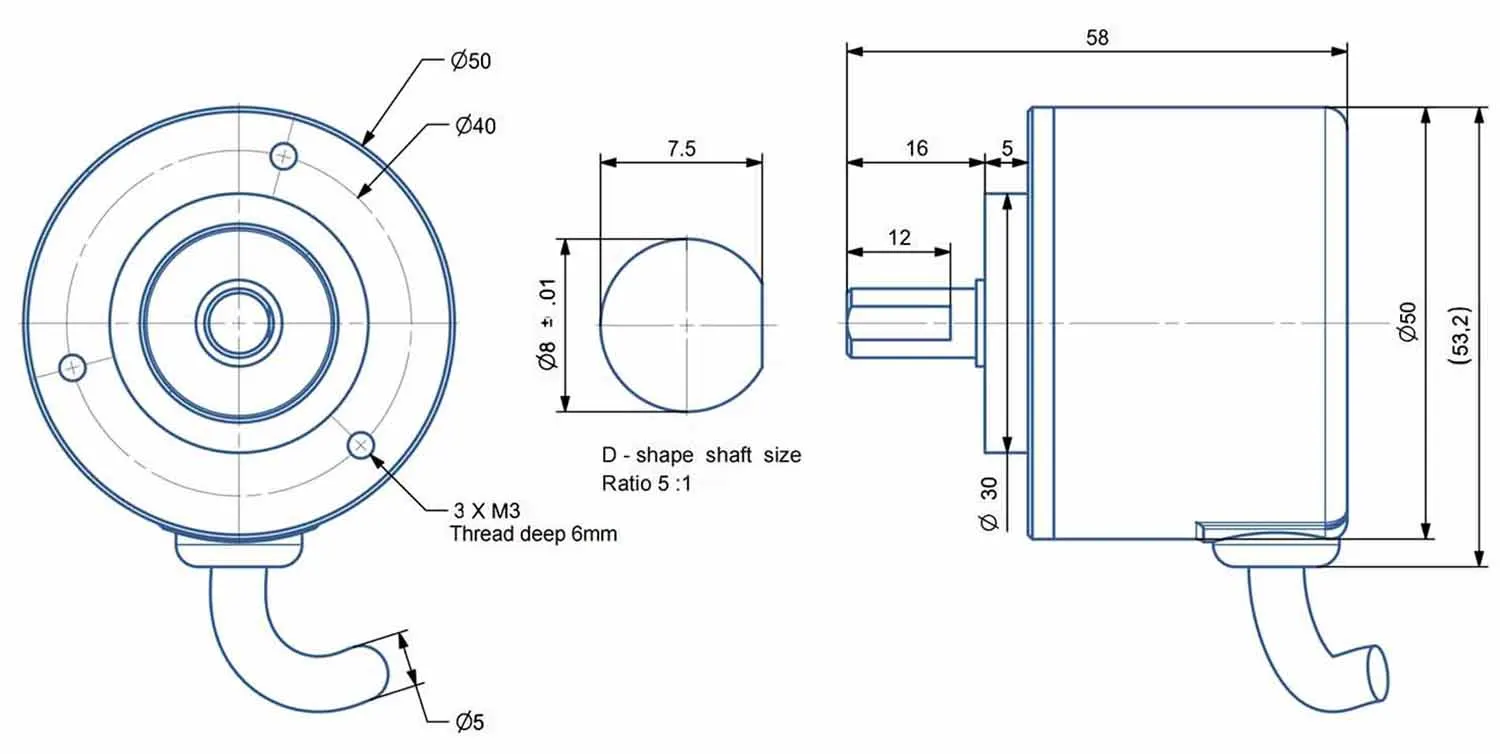
More information, please visit: www.briterencoder.com
More information, Please visit: www.buruiter.com
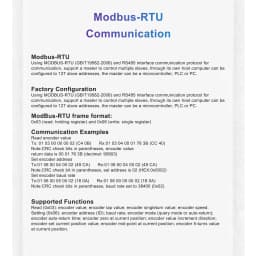
Modbus-RTU Communication
Simple, compact frame format and easy-to-understand, high anti-interference capability.
1.Modbus-RTU
Using MODBUS-RTU (GB/T19582-2008) and RS485 interface communication protocol for communication, support a master to control multiple slaves, through its own host computer can be configured to 127 slave addresses, the master can be a microcontroller, PLC or PC.
2.Factory Configuration
Communication interface: RS485
Baud rate: 9600bps (Baud rate can be configured from 9600~115200bps)
Data bits: 8 Checksum: no checksum
Stop bit: 1 Communication address (ID): 01
3.MODBUS-RTU frame format:
0x03 (read: holding register) and 0x06 (write: single register)
4.Communication Examples
Read encoder value
Tx: 01 03 00 00 00 02 (C4 0B)
Rx:01 03 04 00 01 76 3B (CC 40)
Note:CRC check bits in parentheses, encoder value return data is 00 01 76 3B (decimal: 95803)
Set encoder address
Tx:01 06 00 04 00 02 (49 CA)
Rx:01 06 00 04 00 02 (49 CA)
Note:CRC check bit in parentheses, set address is 02 (HEX:0x0002)
Set encoder baud rate
Tx:01 06 00 05 00 02 (18 0A)
Rx:01 06 00 05 00 02 (18 0A)
Note:CRC check bits in parentheses, baud rate set to 38400 (0x02)
5.Supported Functions
1) Read (0x03): encoder value; encoder lap value; encoder singleturn value; encoder speed.
2)Setting (0x06): encoder address (ID); baud rate; encoder mode (query mode or auto-return); encoder auto-return time; encoder zero at current position; encoder value increment direction; encoder set current position value; encoder mid-point at current position; encoder 5-turns value at current position.
CANbus Communication
High communication speed; strong information integration capability, easy to use.
1. CANbus Description
CAN means Controller Area Network, is one of the most widely used field buses in the world and was first proposed by Bosch in Germany.
2. Factory Configurations
Baud rate: 500kbps (1Mbps, 250kbps,125kbps,100kbps settable)
Frame lD (lD): 01 Standard frame format
3.CANbus data frame format
Example of sending data format
Data field: 0x04 (data length)+ 0x01(encoder address)+0x01(instruction code)+0x00(data 1)
Example of return data format
Data field: 0X07 (data length)+ 0X01 (encoder address) +0X01(instruction code)+0x00012345(data)1
4.Communication Examples
Read encoder value
Send:[0X04][0X011[0X011[0X00]
Back:[0X07][0X011[0X01][0X45][0X23][0X01][0X00]Encoder value:0X00012345ihexadecimal:74565)
Set baud rateSend:[0x04][0X01][0X03][0X01]
Back:[0x04][0X01][0X03][0X00]
Set baud rate: 1M
Setting the position value to zero
Send:[0X04][0X011[0X06][0X00]
Back:[0X04][0X011[0X06][0X00]
5. Support Function
1)Reads: encoder value;encoder lap value; encodersingleturn value; encoder rotational speed.
2)Settings: encoder address(lD); baud rate; encoder mode(query mode or auto-return; encoder auto-return time; takes current position a5 zero; encoder value increment direction; sets the current position value, encoder takes the current position as the center point; encoder takes the current position as the value of 5 turns.
CANopen Communication
High, Interference immunity, excellent network performance, flexible configuration
1. CANopen Description
CANopen port with real-time bi-directional communication capability, CANopen port rotary encoders are compatible with CAN2.0 electrical specifications. Users can set the encoder's lD address, zero point, data transmission mode and other parameters through commands.
2. EDS File
The single-turn and multi-turn EDS files can be downloaded from our website. Please install the EDS file on the CANopenhost controller before use.
3. Communication Objects
1) Network Management NMT: The NMT master controller controls the NMT status of the NMT slave devices.
2) Process Data Object PDO: Used to transfer real-time data.
3) Service Data Object SDO: Object dictionary for direct access to CANopen devices.
4) Special Function Objects: Synchronous Transmission (Sync): Provides a basic network synchronization mechanism. Using this service, the master controller can send real-time data.
5) EMERGENCY: Use this object whenever an error occurs.Node guard: Used to view the operational status of slave devices
6) The relationship between the device status and the communication object.
SSI Communication
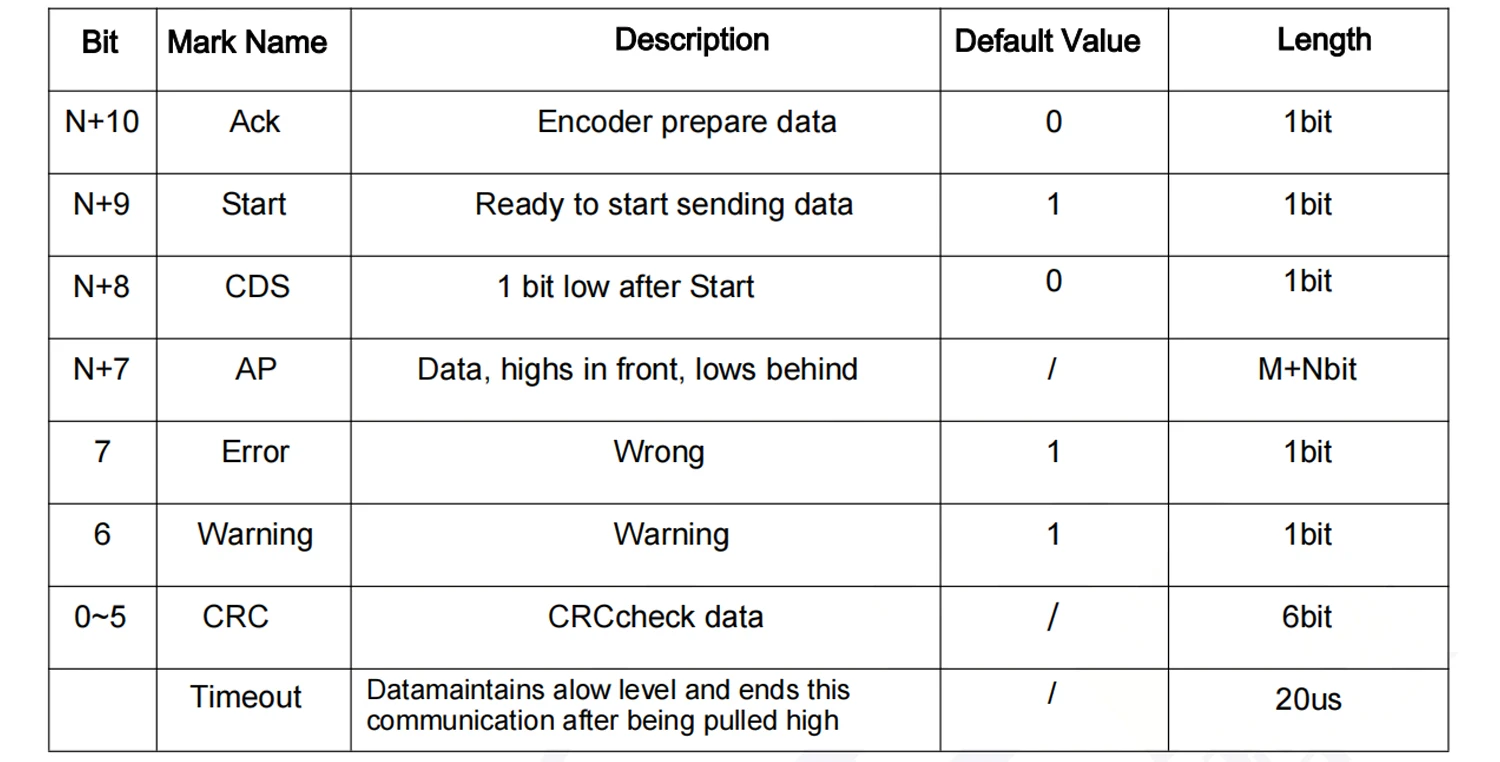
The SSI communication frame is as follows:
the controller sends out a drive signal, the encoder sends out a data signal, when complete one BISS communication frame means that the controller receives a frame of data.
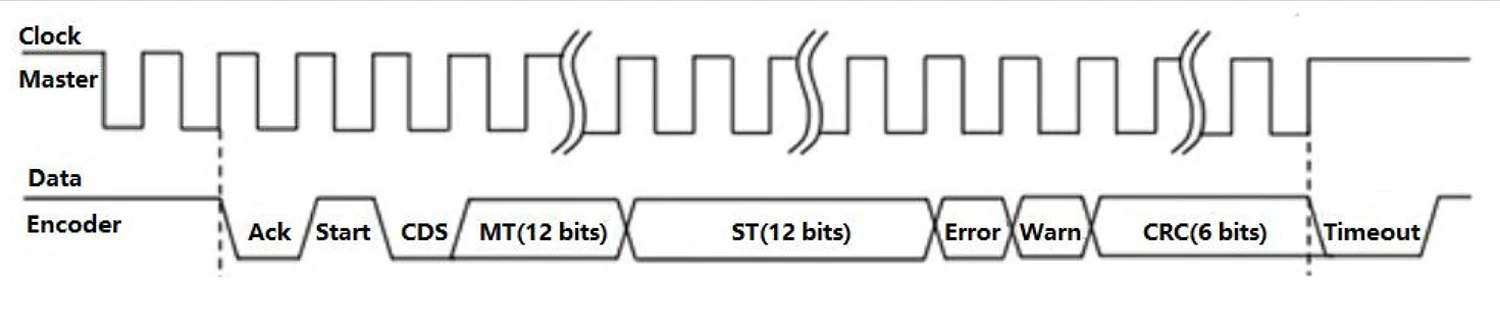
Description
Analog Communication
Direct output values for current, voltage and resistance
The voltage, current and resistance signals of the encoder are collectively referred to as analog signals, and analog signals are widely used in industrial control systems in the automation industry. For the site environment is complex, interference is more serious or the need for long-distance transmission of special occasions, it is recommended that priority be given to electric analog sensors.
Related Certification
Dual-layer magnetic shielding protection, EMC tested
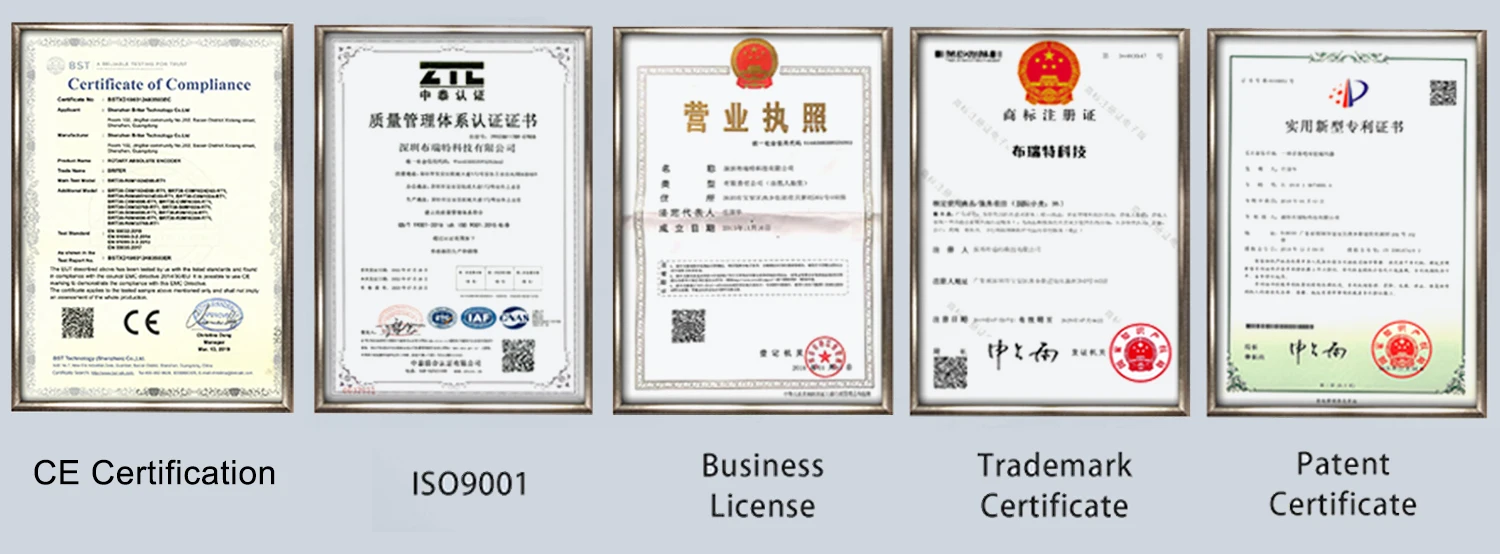
SHENZHEN BRITER TECHNOLOGY CO., LTD is committed to become a core technology to master the high-end encoder and rope displacement sensor R&D and manufacturing enterprises. The company has 10 years of R&D experience, mature technology accumulation, with a number of patented technologies. The company has been committed to creating domestic high-quality products, is committed to become the domestic encoder brand leader.
For more Information (Manuals, Related Video, Drawings) .
Please visit our official website, or you can email to:
Official website:www.briterencoder.com
Customer Reviews
No reviews yet
27mm Absolute Rotary Encoder RS485 RS232 CAN CANopen Modbus RTU Communication 6mm Solid Shaft IP54
80.19$
60.15$
Quantity:
1
Availability:
Color
Model Number
Ships From